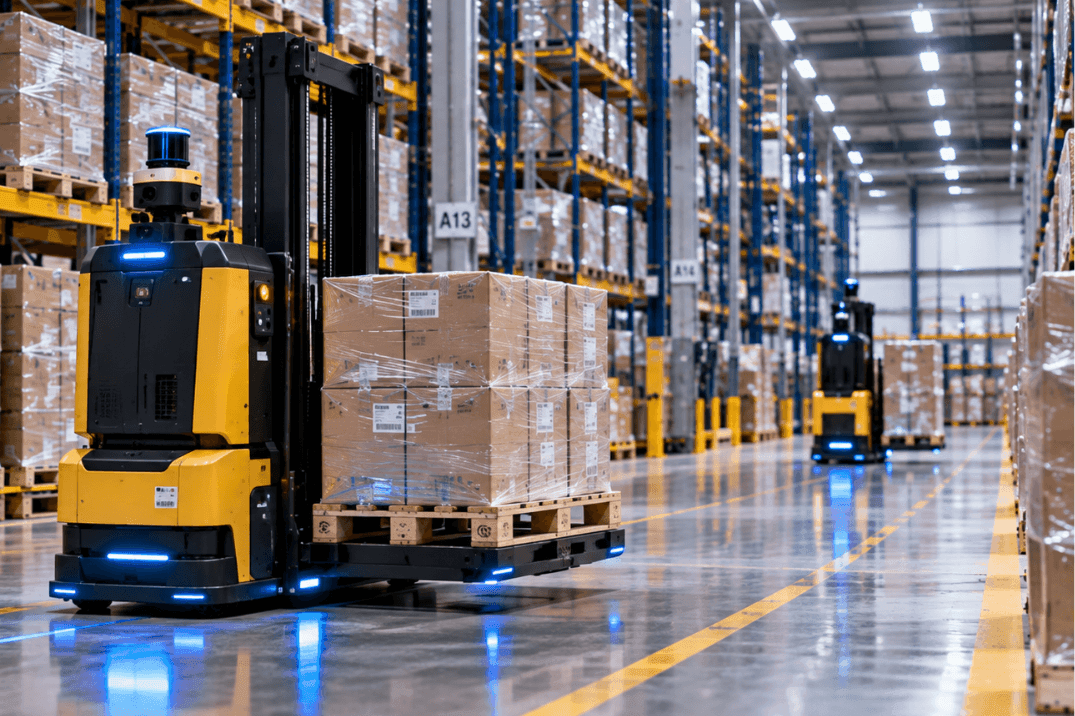
Driverless AGV forklift transporting palletised goods through a modern automated warehouse.

AGV Navigation: Magnetic, Laser & Natural (SLAM) Compared

The performance of an automated guided vehicle rests on one design decision more than any other: how the vehicle knows where it is and where it needs to go next. AGVs are increasingly deployed across UK warehouse and manufacturing operations to absorb repetitive transport tasks, from pallet movements between production and despatch to line-side component feeding. AGV navigation methods differ in cost, flexibility and tolerance of change, and the wrong navigation method can constrain an otherwise well-specified system for years.

Key points
✓What it is: AGV navigation combines guidance infrastructure, onboard sensors and a control system so the vehicle always knows where it is and where to go next.
✓Three methods dominate: Magnetic, laser and natural feature navigation (SLAM) account for almost all industrial AGV deployments.
✓Cost vs flexibility: Magnetic is the cheapest and most repeatable; laser is flexible with a surveyed reflector map; SLAM needs no infrastructure and underpins most Autonomous Mobile Robots (AMRs).
✓Right fit: The best method matches route stability, building geometry and the accuracy you need at transfer.
✓Hybrids are rising: A growing number of AGVs switch navigation method along a single route.

What Is AGV Navigation?

AGV navigation describes the combination of guidance infrastructure, onboard sensors and control system software that lets an automated guided vehicle follow a defined route and position itself accurately at pick and drop locations. Three approaches dominate industrial deployments: magnetic guidance, laser guidance, and natural feature navigation using simultaneous localisation and mapping (SLAM). Each strikes a different balance between intelligence built into the environment and intelligence carried on the vehicle.


That balance dictates what happens when the operation changes. Fixed infrastructure keeps vehicle cost low but ties routes to the floor. Onboard intelligence costs more per vehicle but lets routes be redrawn in software, which matters on sites where product flow shifts through the year.

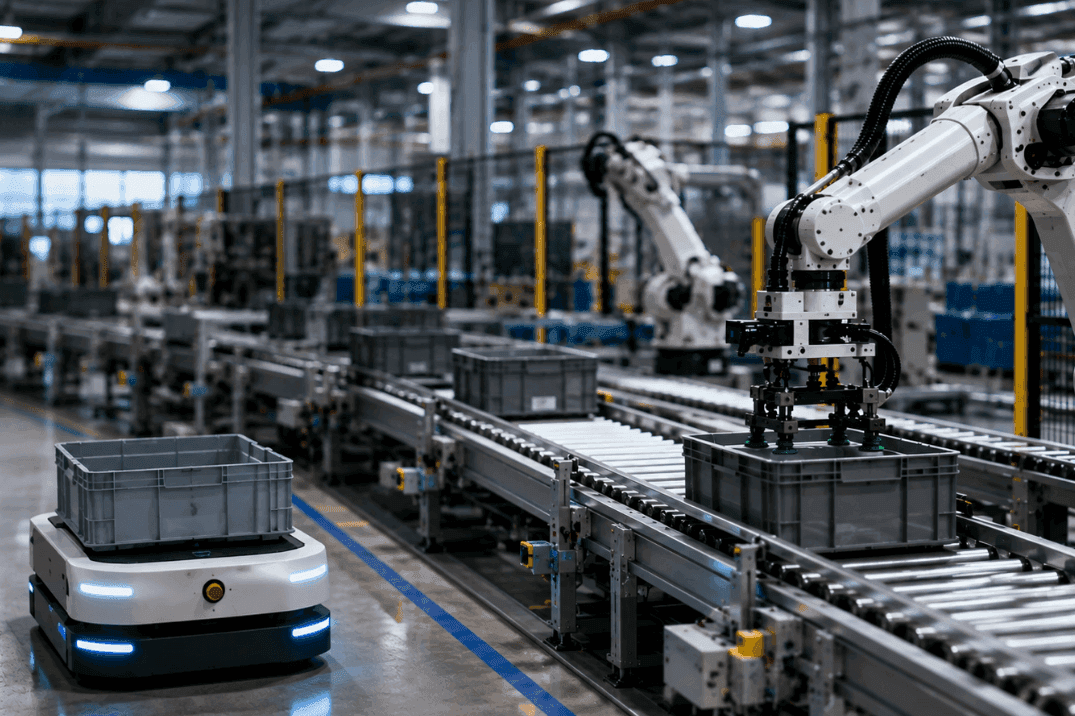
Automated guided vehicle moving palletised goods alongside warehouse staff and conveyor systems.

Magnetic AGV Navigation


Magnetic guidance uses tape or embedded wire laid into the floor, tracked by a magnetic sensor array beneath the vehicle. RFID tags or magnetic markers along the route trigger actions such as stopping, turning, lifting or handing a load to a conveyor system. It remains the most cost-effective and repeatable option for stable, high-volume routes.

Positional accuracy

Tracking a physical reference gives consistent repeatability at transfer points, typically within a few millimetres.

Environmental tolerance

Performance is unaffected by dust, poor lighting, reflective surfaces or changes to rack layouts above floor level.

Low vehicle cost

Sensing requirements are minimal, which keeps the cost of scaling a fleet manageable.

Route rigidity

Layout changes mean relaying the tape or wire, and tape in high-traffic aisles needs periodic replacement.

Laser-Guided AGV Navigation

Laser navigation uses rotating laser scanners mounted on a mast to triangulate the vehicle’s position from reflective targets fixed to walls, columns and racking. Position is calculated continuously against a surveyed map of those reflectors, giving accuracy comparable to magnetic guidance without marking the floor.


Routes can be reconfigured in software provided enough reflectors stay in view, which suits sites where product flow shifts seasonally. The trade-off sits in the reference layer: the reflector survey takes time, and obstruction of targets by stacked stock, temporary structures or new mezzanine steelwork will degrade localisation. Laser navigation is well established in cold storage, paper and beverage operations where long straight runs and stable building fabric play to its strengths.

Driverless AGV forklift moving a pallet along a designated route in a modern distribution centre.

Natural Feature Navigation and SLAM

Natural feature navigation removes fixed references altogether. Onboard LiDAR, sometimes supported by 3D cameras, compares live scans against a stored map of the building’s existing geometry: walls, columns and racking uprights. SLAM lets a vehicle build and update that map while simultaneously locating itself within it.


This is the approach behind most Autonomous Mobile Robots (AMRs), where the vehicle uses dynamic path planning to route around an obstruction rather than stopping in front of it. Deployment is quicker because there is no infrastructure to install, and route changes are made in software. Feature-poor environments are the limitation: wide open floors, long featureless walls and areas where stock arrangement changes daily can all reduce localisation confidence.

3
navigation methods dominate industrial AGVs: magnetic, laser and SLAM
±mm
repeatability at pick and drop with magnetic guidance
0
fixed floor infrastructure required for SLAM navigation
24/7
unmanned running once routes and safety zones are set

How AGVs Are Controlled and Kept Safe

Whichever navigation method is chosen, a central control system, often called an AGV management system, assigns tasks, manages traffic at intersections and schedules charging. This control layer links the fleet to warehouse control software and hands loads to conveyor systems, lifts and automated storage at each transfer point. On the vehicle itself, safety laser scanners and defined stop zones provide the functional safety needed to run alongside people and manual trucks.

How to Choose the Right AGV Navigation Method


Selection should follow the operation rather than the technology. A small number of factors carry most of the weight.

Route stability

Fixed, repetitive flows favour magnetic guidance; frequently changing flows favour natural feature navigation.

Building environment

Feature density, floor condition and available wall space constrain which methods localise reliably.

Accuracy at transfer

Docking with conveyor systems, lifts or automated storage demands tighter repeatability than open-floor transport.

Fleet size

Infrastructure costs amortise across large fleets, whereas onboard sensing costs repeat on every vehicle.

Pedestrian interaction

Shared aisles with manual forklift and foot traffic benefit from the obstacle avoidance built into SLAM-based vehicles.

Hybrid arrangements are common in practice: natural feature navigation handles open transport runs, with magnetic markers or floor codes used at docking positions where sub-centimetre repeatability is required.

Building a Long-Term Case for AGV Navigation

AGV technology continues to converge, with a growing number of vehicles supporting more than one navigation method and switching between them along a single route. 


The decision rests less on which navigation technology is most advanced and more on which best matches the stability, geometry and throughput of the operation, since that match determines flexibility and return over a decade of service. Speak with a specialist to align AGV navigation with your site conditions and material flow.

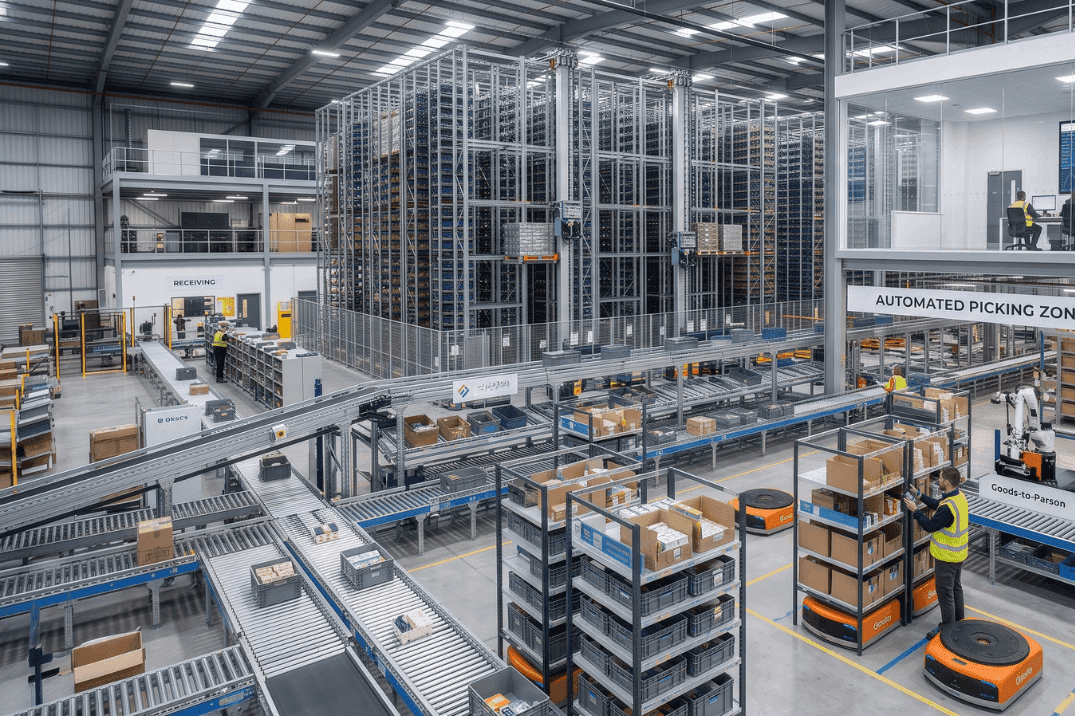
Automated warehouse with conveyor systems, high-bay ASRS and goods-to-person AMRs picking orders

Specifying an AGV system?

Our team can match magnetic, laser or SLAM navigation to your routes, building and throughput, then integrate it with your wider automation.

Speak to a specialist

Offline Robot Programming FAQs